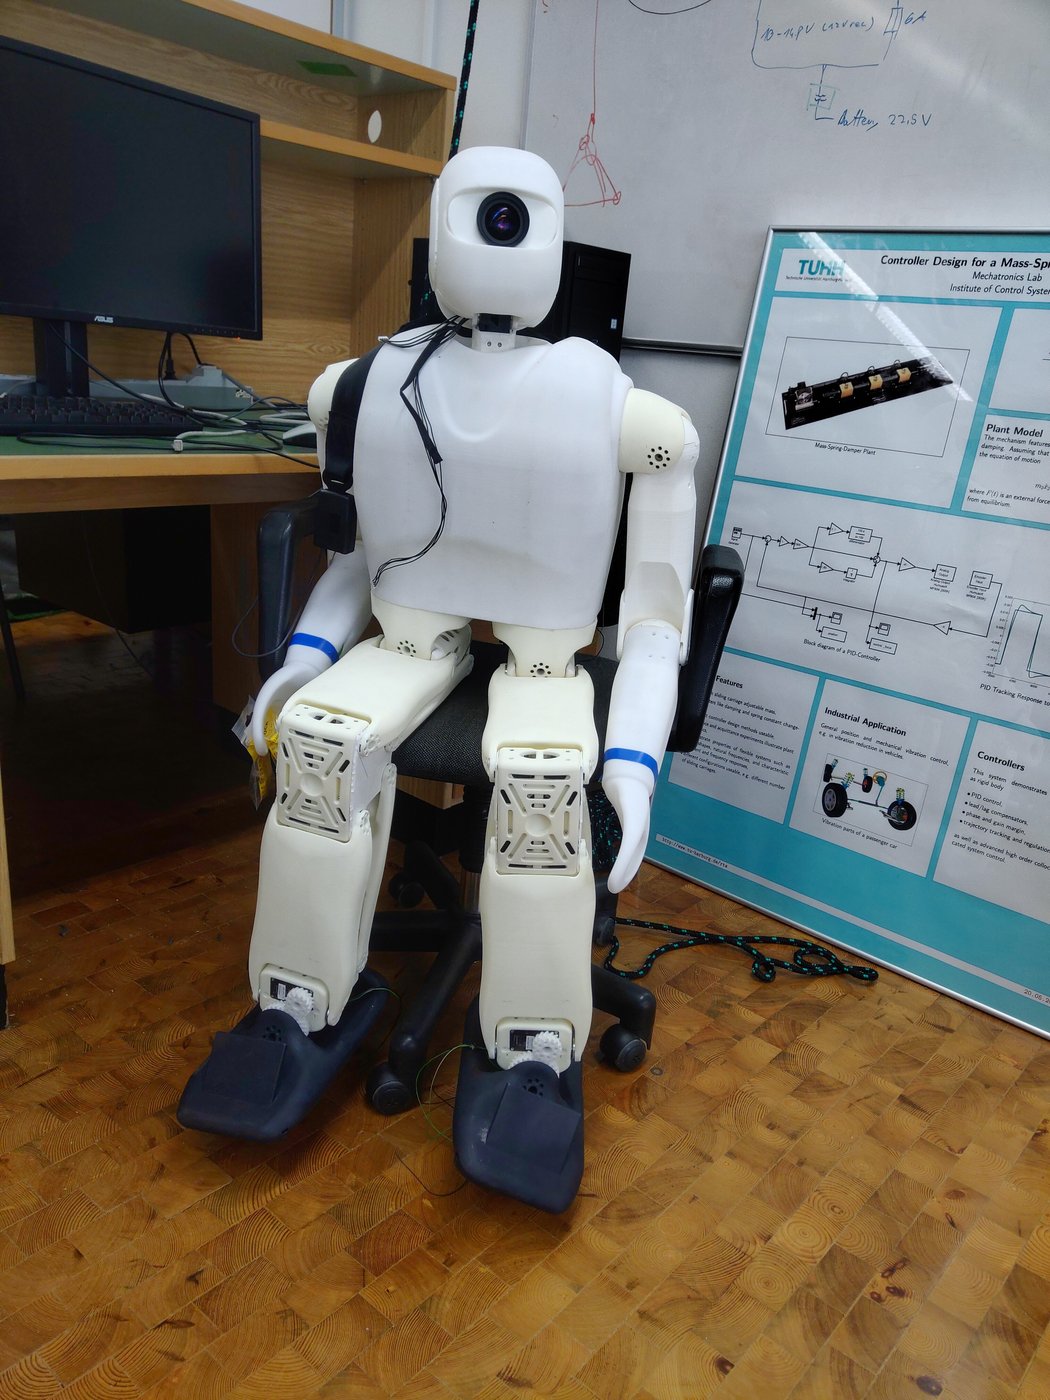
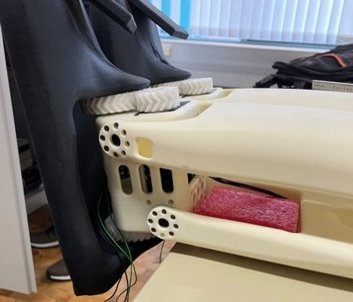
The humanoid robot in the lab
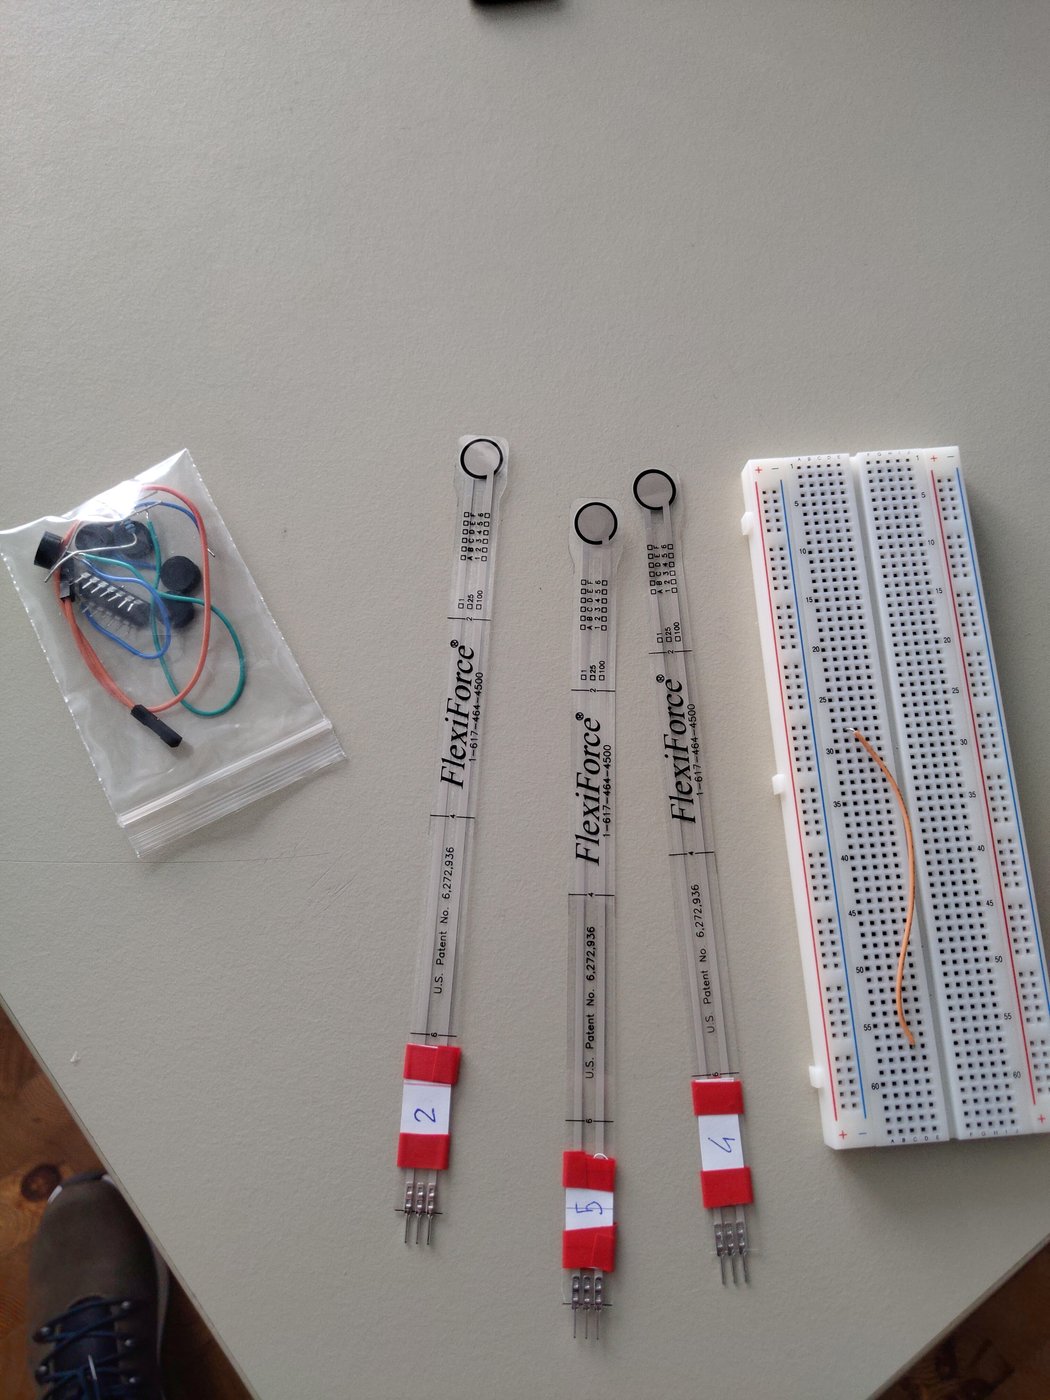
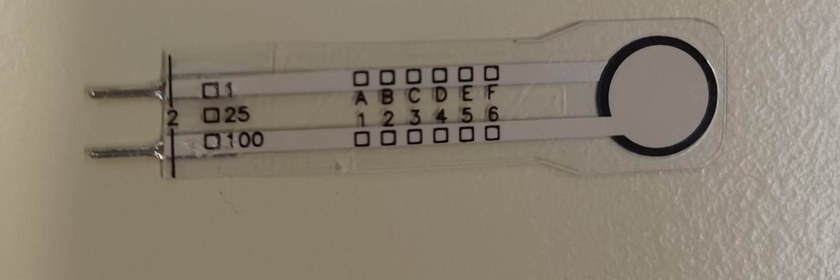
FlexiForce force sensors used for the feet

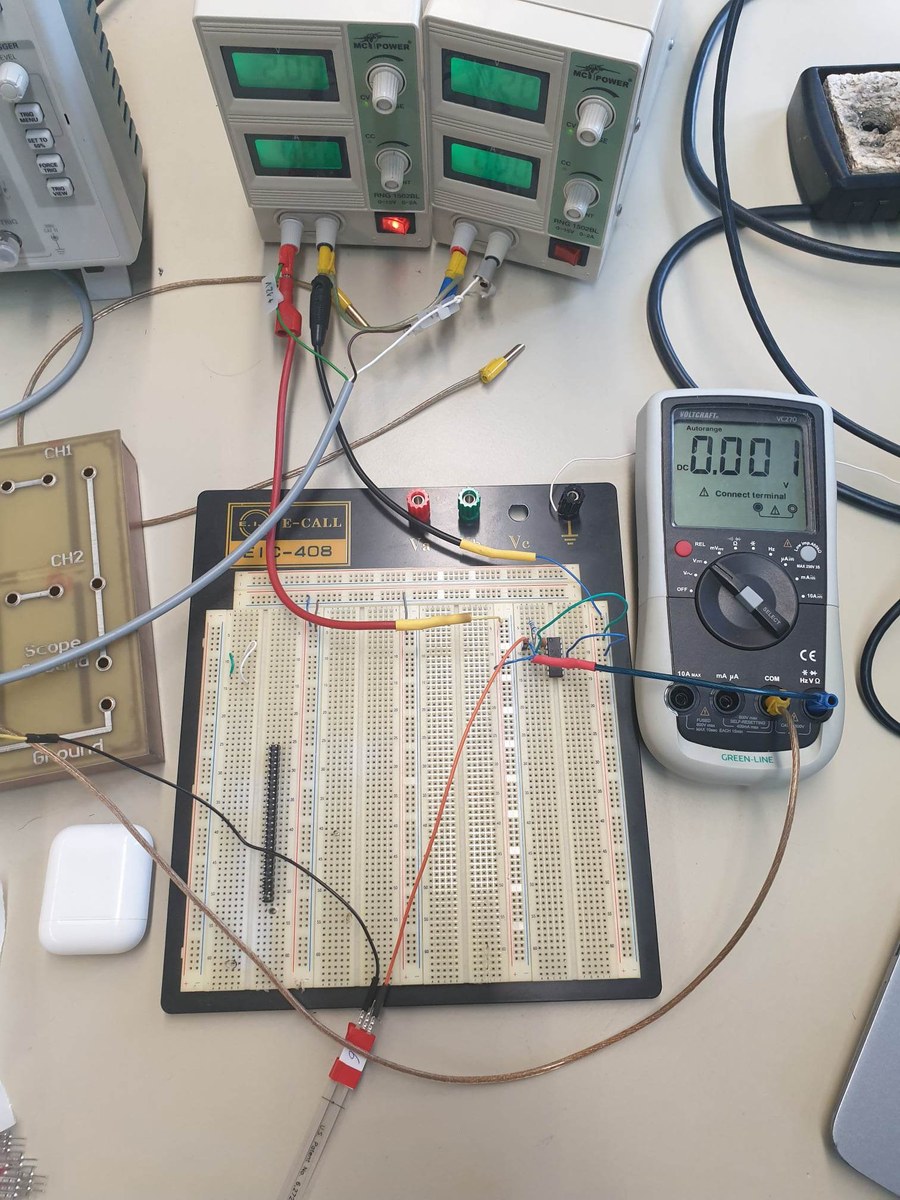
Bench test setup with power supplies, breadboard and multimeter
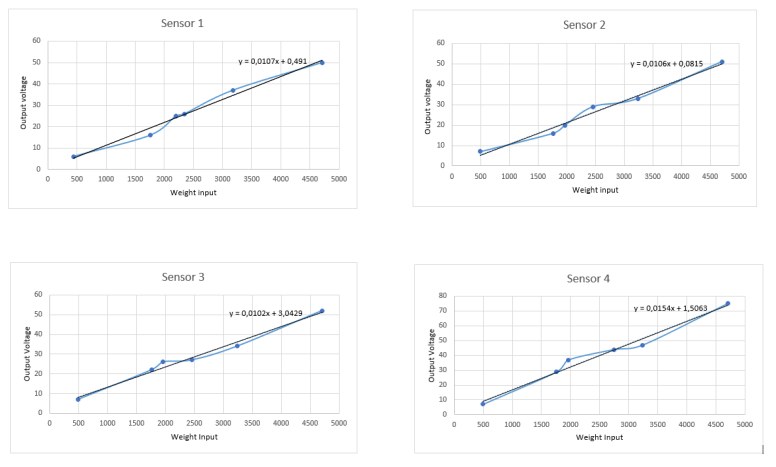
Calibration curves of the four sensors with linear fits

Shortened FlexiForce sensor
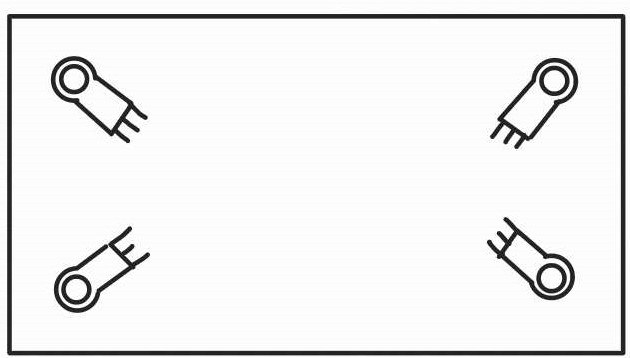
Layout of four sensors under the foot
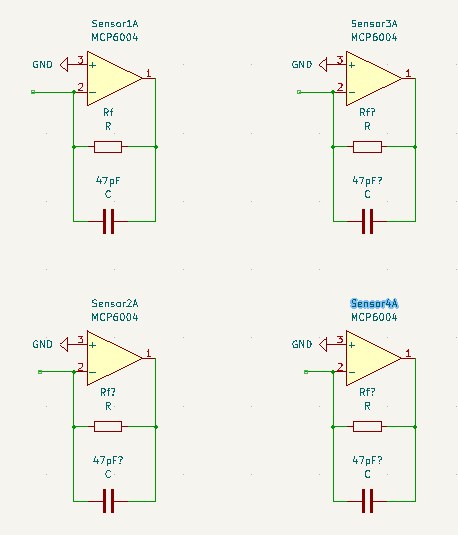
Schematic of the four-channel MCP6004 amplifier
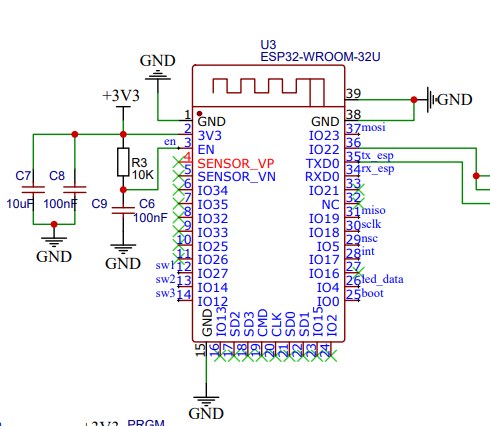
Schematic of the ESP32 used for reading the sensors

Chosen PCB location at the back of the calf

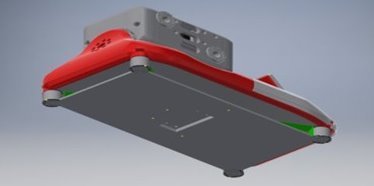
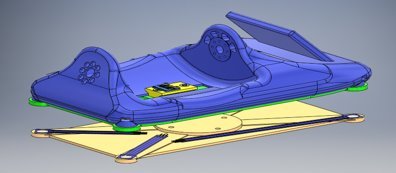
Foot sensor mount, version 1
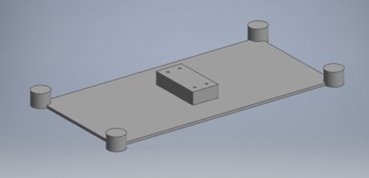
Foot sensor mount, version 1, sole plate with pucks

Foot sensor mount, version 2
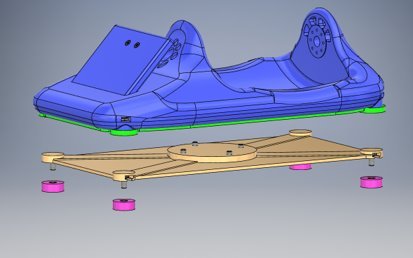
Foot sensor mount, version 2, exploded view

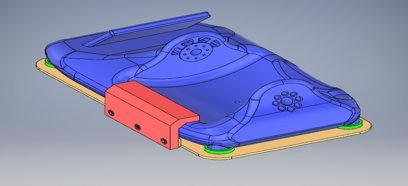
Final foot sensor mount, exploded view with studs
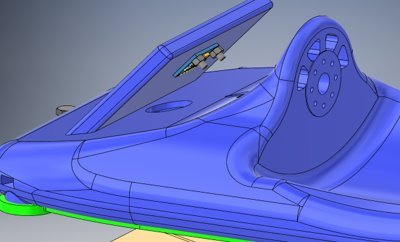
Final foot sensor mount with IMU position